The Direct Indicating Compass
by Ghost Aviator
Table of Contents
- The Magnetic Compass and Direct Indicating Compass
- The Vertical Card Compass
- Compass Requirements – Horizontality, Sensitivity, Aperiodicity
- The Compass Liquid
- Deviation and Accuracy
- Acceleration and Turning Errors – Theory
- Errors Caused by Linear Acceleration
- Summary of Acceleration Errors
- Turning Errors
- Turning Errors – Liquid Swirl
- Summary of Turning Errors
- Practice Questions & Detailed Answers
- Master Reference Tables
1. The Magnetic Compass and Direct Indicating Compass
A compass indicates direction relative to a known datum. The magnetic compass uses the horizontal component (H) of the earth's magnetic field as its directional datum. Unfortunately, this datum (the magnetic meridian) is generally not aligned with the true meridian — the angular difference between them is magnetic variation.
Additionally, iron/steel components and electric currents in the aircraft distort the earth's field locally, causing the compass magnet to deviate from the magnetic meridian. This is compass deviation.
2. The Vertical Card Compass
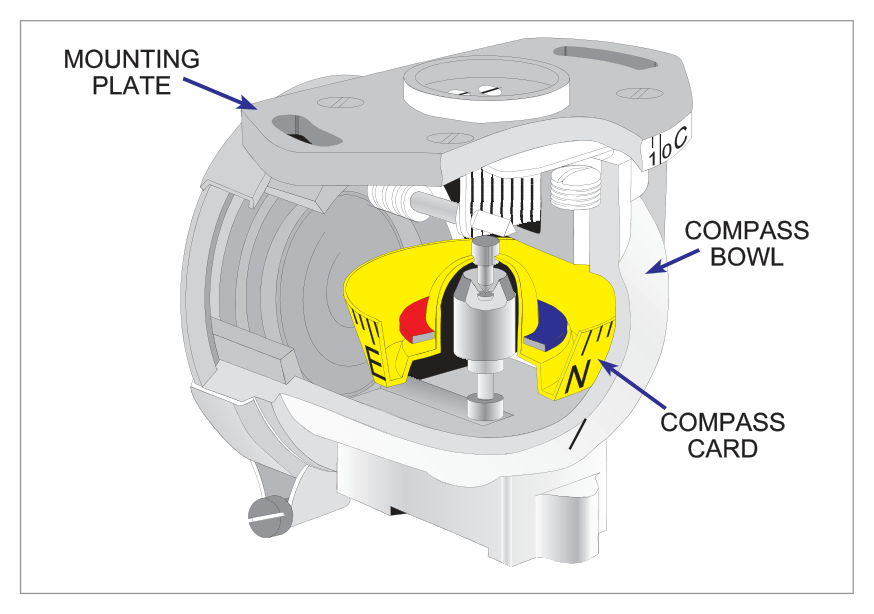
The vertical card compass (B-type / E-type) is the standard direct reading compass for general use — the main magnetic heading reference in light aircraft and the standby compass in larger aircraft.
- A circular compass card is attached directly to the magnet assembly.
- The combined unit is suspended in liquid within the compass bowl.
- A vertical lubber line on the glass window enables heading to be read off the rotating card.
3. Compass Requirements – Horizontality, Sensitivity, Aperiodicity
3.1 Horizontality
The magnets must lie as nearly as possible in the horizontal plane. A freely suspended magnet would align with the total field T and dip — only horizontal at the magnetic equator. To achieve horizontality, the assembly is pendulously suspended: the centre of gravity (CG) is below the supporting pivot.
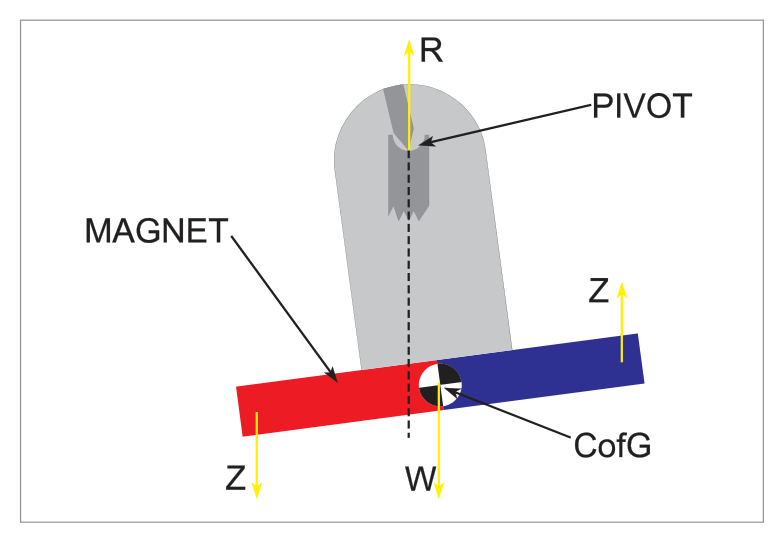
Two couples act: (1) Z pulling the red end downward; (2) the weight W acting down through CG (displaced by tilt) and reaction R upward through pivot. Equilibrium results in a residual tilt of approximately 2° (red/north end down) in mid-latitudes, Northern Hemisphere. (Blue/south end down in Southern Hemisphere.)
3.2 Sensitivity
The compass must seek the horizontal component H in all areas except near the poles. Sensitivity is increased by:
- Using two, four, or six short magnets or a circular magnet (high pole strength alloy)
- Iridium-tipped pivot in a jewelled cup (reduces friction)
- Lubrication from the compass liquid
- Reduced effective weight through liquid buoyancy
3.3 Aperiodicity (Dead Beat)
The assembly must settle quickly after being disturbed, with oscillations rapidly damped. Achieved by:
- Several short magnets (mass near centre → low moment of inertia → easier to damp)
- Light alloy framework to minimise weight
- Compass liquid acts as primary damping medium
- Grid ring compass adds damping wires for faster damping than vertical card type
4. The Compass Liquid
The liquid is essential — it dampens oscillations and lubricates the pivot. Required properties:
- Low coefficient of expansion (temperature changes cause expansion — handled by an expansion chamber or Sylphon tube)
- Low viscosity (to minimise liquid swirl — discussed later)
- Transparency
- Low freezing point
- High boiling point
- Non-corrosive
5. Deviation and Accuracy
Deviation is produced by the iron/steel components in the aircraft distorting the earth's field. It is the angle between the local magnetic meridian and the direction in which the compass magnets are lying.
- East (+) deviation: North-seeking (red) ends point EAST of magnetic north
- West (−) deviation: North-seeking ends point WEST of magnetic north
- Deviation varies with heading — must be measured on multiple headings (compass swing)
- Residual deviation after swing is recorded on the compass deviation card in the aircraft
During the swing, normal flying conditions should be simulated: engines running, electrical/radio services on, aircraft in level flight attitude. Ferromagnetic tools, watches, and objects must not be near the compass during a swing.
6. Acceleration and Turning Errors – Theory
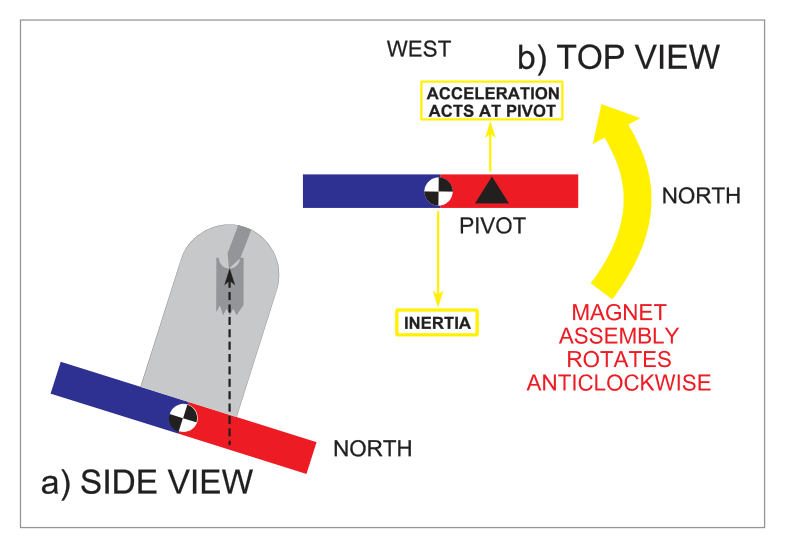
Acceleration and turning errors occur whenever the CG of the magnet assembly moves away from its normal position almost directly below the pivot. When the CG is displaced, the earth's vertical component Z exerts a torque about the pivot, rotating the magnet assembly and producing a false heading indication.
No error occurs when the manoeuvre displaces the CG north or south (in the plane of the magnetic meridian) — only the north-south tilt changes, with no azimuth rotation.
7. Errors Caused by Linear Acceleration
7.1 Acceleration on 270°M (Northern Hemisphere)
The inertia of the pendulously suspended assembly causes it to swing back behind the pivot (which is north of the CG). Z produces an anticlockwise rotation → compass over-reads → indicates an apparent turn towards north. Example: real heading 270°, compass reads ~280°.
7.2 Acceleration on 090°M (Northern Hemisphere)
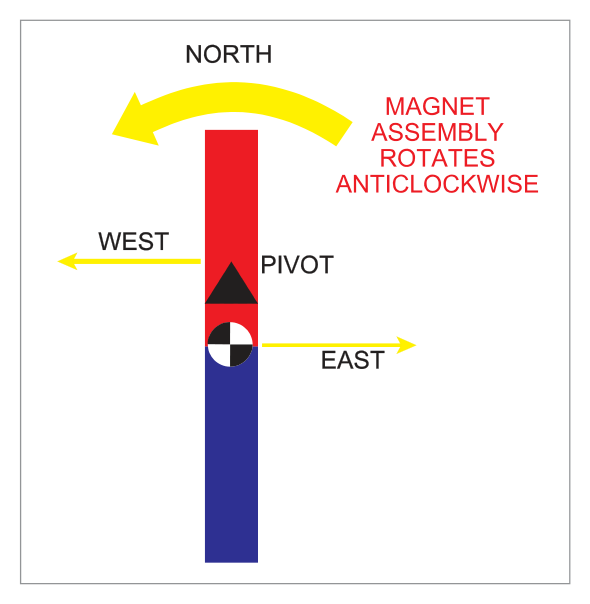
Inertia causes assembly to swing back → clockwise rotation → compass under-reads → indicates apparent turn towards north. Example: real heading 090°, compass reads ~080°.
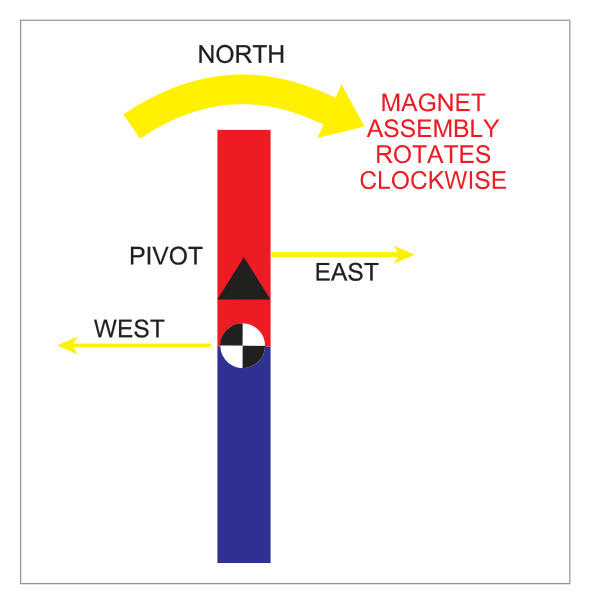
7.3 Deceleration on 090°M (Northern Hemisphere)
Inertia causes assembly to swing forward → anticlockwise rotation → compass over-reads → apparent turn towards south.
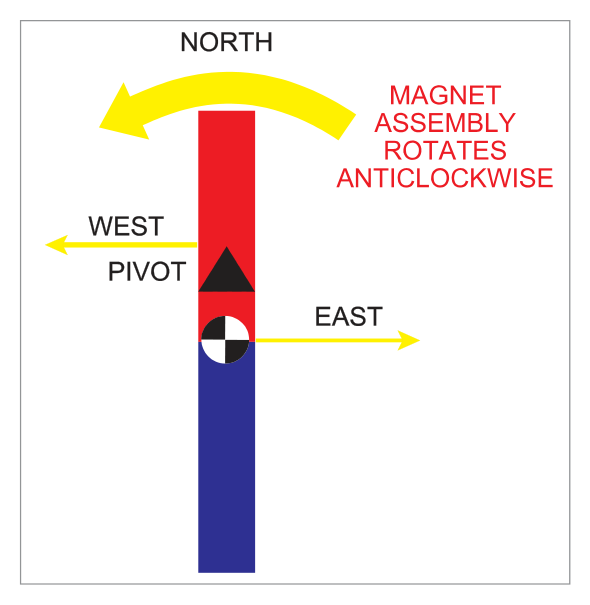
7.4 Acceleration on 270°M (Southern Hemisphere)
Now the pivot is offset to the south of the CG (blue/south-seeking end dips down). Inertia swings assembly back → clockwise rotation → compass under-reads → apparent turn towards south.
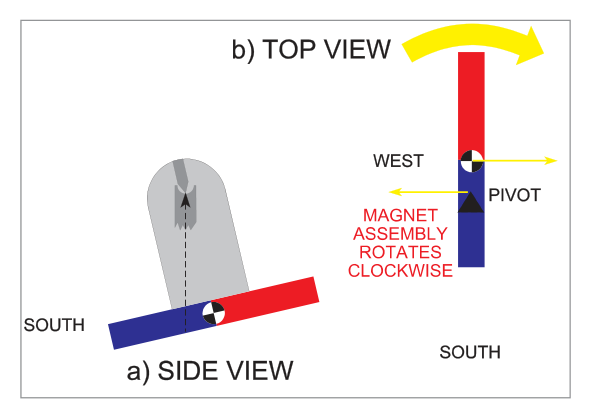
7.5 Acceleration on a Northerly Heading (Northern Hemisphere)
CG lags — but the CG and pivot remain in the plane of the magnetic meridian → only a change in N/S tilt → no error.
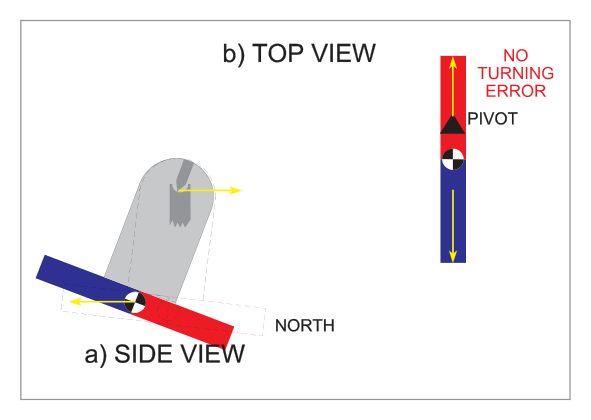
8. Summary of Acceleration Errors
- Zero on N/S headings (both hemispheres)
- Maximum on E/W headings (090°M and 270°M)
- Acceleration → apparent turn towards the nearer pole (north in NH, south in SH)
- Deceleration → apparent turn towards the further pole (south in NH, north in SH)
- Clockwise displacement of magnet assembly → compass under-reads
- Anticlockwise displacement → compass over-reads
flowchart TD
    A["Linear Acceleration"] --> B{"Heading?"}
    B -->|N or S| C["No Error
(CG stays in meridian plane)"]
    B -->|E or W| D["Maximum Error"]
    D --> E{"Hemisphere?"}
    E -->|NH, accel| F["Apparent turn NORTH
(towards nearer pole)"]
    E -->|NH, decel| G["Apparent turn SOUTH
(towards further pole)"]
    E -->|SH, accel| H["Apparent turn SOUTH
(towards nearer pole)"]
    E -->|SH, decel| I["Apparent turn NORTH
(towards further pole)"]
9. Turning Errors
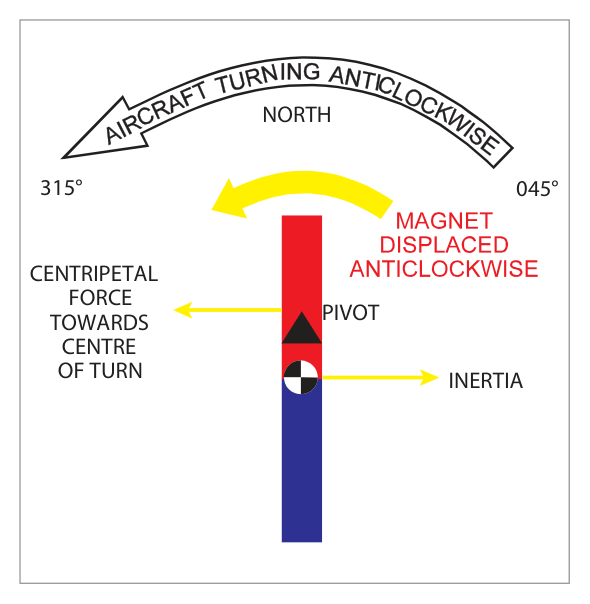
In a turn, centripetal force acts through the pivot towards the centre of the turn; centrifugal (inertial) force acts outward through the CG. This causes the magnet assembly to "swing out" from the turn, rotating it around the pivot.
9.1 Key Terminology
- Sluggish compass: Aircraft and magnet assembly rotate in the same direction → fewer degrees pass under lubber line than actual heading change → pilot must undershoot (roll out early)
- Lively compass: Aircraft and magnet assembly rotate in opposite directions → more degrees pass under lubber line than actual heading change → pilot must overshoot (roll out late)
- Clockwise magnet rotation → compass under-reads
- Anticlockwise magnet rotation → compass over-reads
9.2 Turning from 045° to 315° through North (NH — Left Turn)
In NH, CG is south of pivot. In a left turn through north, inertia throws magnet assembly anticlockwise. Aircraft and magnet rotate in same direction → compass is sluggish. Anticlockwise → over-reads. Pilot sees fewer than 90° pass → must undershoot. Stop at ~335° indicated to achieve 315° actual.
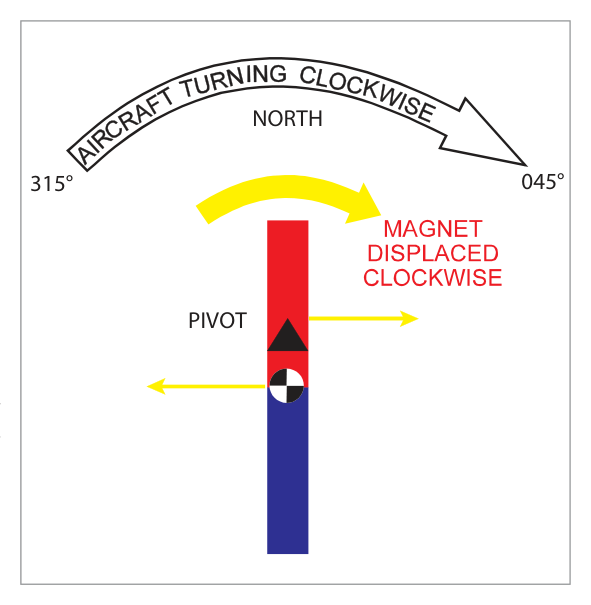
9.3 Turning from 315° to 045° through North (NH — Right Turn)
Inertia throws assembly clockwise. Same direction as aircraft → sluggish. Clockwise → under-reads. Stop at ~025° indicated to achieve 045° actual. Must undershoot.
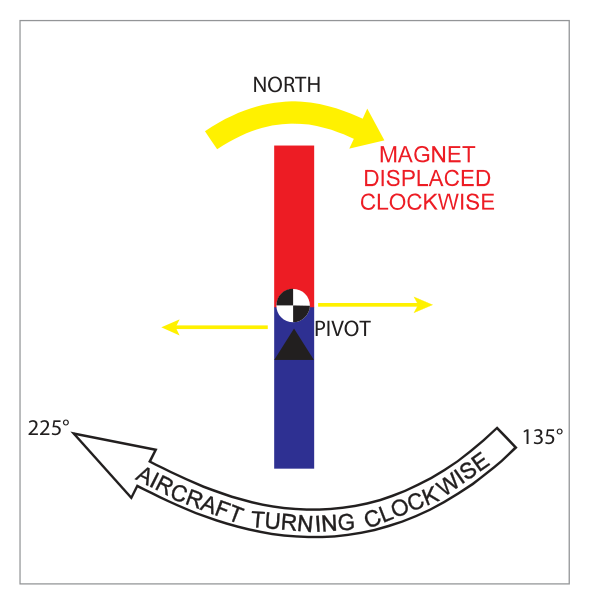
9.4 Turning from 135° to 225° through South (NH — Right Turn)
Aircraft turns right (clockwise) but inertia throws magnet anticlockwise (opposite direction to aircraft) → compass is lively. Anticlockwise → over-reads. Pilot sees more than 90° pass → must overshoot. Stop at ~245° indicated to achieve 225° actual.
9.5 Turning from 135° to 225° through South (SH — Right Turn)
In SH, CG is north of pivot (blue end dips toward south pole). Inertia throws magnet clockwise. Same direction as aircraft → sluggish. Must undershoot. Stop at ~205° to achieve 225°.
9.6 Turning through East or West (No Error)
Magnets are tilted north-south but this tilt is in the vertical plane of the magnetic meridian through the pivot. There is no rotational couple about the pivot → turning error is zero when passing through east or west.
10. Turning Errors – Liquid Swirl
During a turn, the liquid in contact with the bowl tends to be dragged around with the bowl, creating eddies that drift inward and deflect the magnet assembly in the direction of the turn.
| Hemisphere | Turning through NORTH | Turning through SOUTH |
|---|---|---|
| NH | Liquid swirl and magnet both turn anticlockwise → swirl INCREASES turning error | Magnet turns anticlockwise, liquid swirl turns clockwise → swirl REDUCES turning error |
| SH | Swirl effect in opposite sense to NH | Swirl INCREASES turning error through nearer pole (south) |
| Magnetic Equator | Only source of turning error is liquid swirl (Z = 0, no dip-based errors) | |
11. Summary of Turning Errors
- Maximum through magnetic north or south; zero through east or west
- Errors increase with increasing magnetic latitude (stronger Z, weaker H)
- At magnetic equator: only liquid swirl error
- Aircraft and compass rotate in same direction
- Compass is sluggish → undershoot (roll out early)
- Liquid swirl increases turning error
- Aircraft and compass rotate in opposite directions
- Compass is lively → overshoot (roll out late)
- Liquid swirl reduces turning error
Magnet displaced CLOCKWISE (viewed from above) → compass UNDER-READS
Magnet displaced ANTICLOCKWISE → compass OVER-READS
- On south, the compass does not indicate the wrong direction of turn as it can on north
- The 'lively' nature of the indications on south reduces the risk of over-correcting small steering errors
flowchart TD
    T["Turning Error"] --> NH["Northern Hemisphere"]
    T --> SH["Southern Hemisphere"]
    NH --> NHP["Turning through North (nearer pole)"]
    NH --> NHS["Turning through South (further pole)"]
    NHP --> NHP1["Sluggish, Undershoot, Swirl INCREASES error"]
    NHS --> NHS1["Lively, Overshoot, Swirl REDUCES error"]
    SH --> SHP["Turning through South (nearer pole)"]
    SH --> SHN["Turning through North (further pole)"]
    SHP --> SHP1["Sluggish, Undershoot, Swirl INCREASES error"]
    SHN --> SHN1["Lively, Overshoot, Swirl REDUCES error"]
- Three compass requirements: Horizontal (pendulous suspension), Sensitive (multi-magnets, iridium pivot, buoyancy), Aperiodic (short magnets, liquid damping).
- Deviation (from aircraft magnetism) varies with heading. Swing records deviation on deviation card. EASA requirement: ±10°.
- Acceleration errors: max E/W, zero N/S. Accel = apparent turn towards nearer pole. Decel = apparent turn towards further pole.
- Turning errors: max through N/S, zero through E/W. Nearer pole = sluggish = undershoot. Further pole = lively = overshoot.
- Liquid swirl: always turns magnet in direction of aircraft turn. Increases error through nearer pole; reduces through further pole.
- Clockwise magnet = under-reads. Anticlockwise = over-reads.
- Magnetic equator: no turning error (only liquid swirl).
Practice Questions & Detailed Answers
- (a) A non-pendulously mounted system would not be horizontal outside the equator — pendulous suspension is essential.
- (b) A single bar magnet is not used — multiple short magnets reduce moment of inertia for better aperiodicity.
- (d) The system must have a HIGH magnetic moment (not low) to be sensitive to the weak directive force H.
- (a) Replaces "aperiodic" with "periodic" — the opposite requirement. An aperiodic (dead-beat) instrument settles quickly; a periodic one would oscillate indefinitely.
- (b) These are design features, not the primary requirements that define compass performance.
- (c) Positioning and deviation correction are operational considerations — not the fundamental physical requirements of the magnet system.
- (a) 180° and 360° are north/south headings → zero acceleration error (CG moves in meridian plane only).
- (b) & (c) 045°/135°/225°/315° are intermediate headings — errors exist but are not maximum.
- (b) The liquid increases aperiodicity (better damping), not decreases it.
- (c) The liquid's sensitivity benefit works at all latitudes, not just high ones. "Lubricate bearings" is partially correct but understates the buoyancy contribution.
- (d) The liquid actually causes liquid swirl — it does not reduce it. Low viscosity minimises swirl, but the liquid inherently introduces some swirl.
- (a) Suspension on the centre line of the magnet would give no pendulous action — the CG and pivot would coincide.
- (b) Suspending from below the CG would be unstable and would not oppose the Z-induced tilt.
- (d) The suspension point is fixed by design — it does not vary with latitude.
- (a), (b), (c) All omit at least one valid factor. Rate of turn (3) matters because faster turns create larger centrifugal displacement. Hemisphere (4) determines which pole is nearer and the direction of the error.
- (a) Away from the nearer pole = through the further pole = liquid swirl reduces error (opposite effect).
- (b) & (c) Liquid swirl always affects turning error to some degree — it cannot be "no effect".
- (a) There IS a small turning error at the equator — liquid swirl provides a slight, direction-dependent error even with no dip.
- (b) Without the Z component at the equator, the north/south distinction does not apply; swirl is the only source and it acts in both turn directions.
- (d) While east/west turning errors are zero at all latitudes (due to no azimuth torque), the question addresses the overall equatorial situation where swirl provides the only error — making option (c) more complete and correct.
Master Reference Tables
| Parameter | Value/Rule | Section |
|---|---|---|
| EASA accuracy requirement | ±10° | §5 |
| Residual tilt in mid-latitudes NH | ~2° (red/N end down) | §3.1 |
| Acceleration error max headings | 090°M and 270°M (E/W) | §8 |
| Acceleration error zero headings | N/S (both hemispheres) | §8 |
| Accel → apparent turn NH | Towards north (nearer pole) | §8 |
| Decel → apparent turn NH | Towards south (further pole) | §8 |
| Turning error max headings | Through N/S | §11 |
| Turning error zero headings | Through E/W | §11 |
| Clockwise magnet displacement | Compass UNDER-reads | §11 |
| Anticlockwise magnet displacement | Compass OVER-reads | §11 |
| Nearer pole → sluggish | UNDERSHOOT (roll out early) | §11 |
| Further pole → lively | OVERSHOOT (roll out late) | §11 |
| Liquid swirl through nearer pole | INCREASES turning error | §10 |
| Liquid swirl through further pole | REDUCES turning error | §10 |
| At magnetic equator | No turning error (only liquid swirl) | §10 |
- Compass requirements: "H.S.A." → Horizontal, Sensitive, Aperiodic
- Acceleration error direction: "ACCeleration → toward Nearer Pole" (ACCNP). "DECeleration → away from Nearer Pole" (DECFP = Further Pole)
- Turning nearer pole: "SLUG = Same direction, Lags, Undershoot, Grows (swirl increases)"
- Turning further pole: "LORE = Lively, Opposite, Roll out late, Early exit reduces swirl"
- Clockwise = Under, Anticlockwise = Over: "CU, AO" (like Copper/Au in chemistry!)
Answer Key
| Q1 | Q2 | Q3 | Q4 | Q5 | Q6 | Q7 | Q8 | Q9 |
|---|---|---|---|---|---|---|---|---|
| c | d | d | d | a | c | d | d | c |
Reinforce Chapter 10: The Direct Indicating Compass
Test your knowledge and practice actual exam questions for Navigation — Instrumentation.